|
MeshLib Java Docs
|
|
MeshLib Java Docs
|
Public Member Functions | |
| Matrix3f (java.lang.foreign.MemorySegment segment, java.lang.Object owner) | |
| Matrix3f | copy () |
| void | set (Matrix3f other) |
| meshlib.Vector3f | x () |
| void | setX (meshlib.Vector3f value) |
| meshlib.Vector3f | y () |
| void | setY (meshlib.Vector3f value) |
| meshlib.Vector3f | z () |
| void | setZ (meshlib.Vector3f value) |
| Matrix3f () | |
| Matrix3f (meshlib.Vector3f x, meshlib.Vector3f y, meshlib.Vector3f z) | |
| Matrix3f (meshlib.Matrix3d m) | |
| meshlib.Vector3f | index (int row) |
| meshlib.Vector3f | index_mut (int row) |
| meshlib.Vector3f | col (int i) |
| float | trace () |
| float | normSq () |
| float | norm () |
| float | det () |
| meshlib.Matrix3f | inverse () |
| meshlib.Matrix3f | transposed () |
| meshlib.Vector3f | toEulerAngles () |
| meshlib.Matrix3_float_QR | qr () |
| Public Member Functions inherited from meshlib.CppStruct | |
| final java.lang.foreign.MemorySegment | rawPointer () |
Static Public Member Functions | |
| static meshlib.Matrix3f | zero () |
| static meshlib.Matrix3f | identity () |
| static meshlib.Matrix3f | scale (float s) |
| static meshlib.Matrix3f | scale (float sx, float sy, float sz) |
| static meshlib.Matrix3f | scale (meshlib.Vector3f s) |
| static meshlib.Matrix3f | rotation (meshlib.Vector3f axis, float angle) |
| static meshlib.Matrix3f | rotation (meshlib.Vector3f from, meshlib.Vector3f to) |
| static meshlib.Matrix3f | rotationFromEuler (meshlib.Vector3f eulerAngles) |
| static meshlib.Matrix3f | approximateLinearRotationMatrixFromEuler (meshlib.Vector3f eulerAngles) |
| static meshlib.Matrix3f | fromRows (meshlib.Vector3f x, meshlib.Vector3f y, meshlib.Vector3f z) |
| static meshlib.Matrix3f | fromColumns (meshlib.Vector3f x, meshlib.Vector3f y, meshlib.Vector3f z) |
Static Public Attributes | |
| static final java.lang.foreign.StructLayout | LAYOUT = meshlib.Ffi.structLayout(new java.lang.String[]{"x", "y", "z"}, new java.lang.foreign.MemoryLayout[]{meshlib.Vector3f.LAYOUT, meshlib.Vector3f.LAYOUT, meshlib.Vector3f.LAYOUT}) |
| static final long | OFF_x = LAYOUT.byteOffset(java.lang.foreign.MemoryLayout.PathElement.groupElement("x")) |
| static final long | OFF_y = LAYOUT.byteOffset(java.lang.foreign.MemoryLayout.PathElement.groupElement("y")) |
| static final long | OFF_z = LAYOUT.byteOffset(java.lang.foreign.MemoryLayout.PathElement.groupElement("z")) |
Additional Inherited Members | |
| Protected Member Functions inherited from meshlib.CppStruct | |
| CppStruct (java.lang.foreign.MemorySegment segment, java.lang.Object owner) | |
| Protected Attributes inherited from meshlib.CppStruct | |
| final java.lang.foreign.MemorySegment | segment |
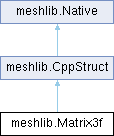
arbitrary 3x3 matrix Generated from class MR::Matrix3f.
Has the same layout as the C++ struct, the fields are accessed in place in native memory.
| meshlib.Matrix3f.Matrix3f | ( | java.lang.foreign.MemorySegment | segment, |
| java.lang.Object | owner ) |
Wraps a segment holding the struct. owner is kept alive as long as this wrapper is. Not for normal use.
| meshlib.Matrix3f.Matrix3f | ( | ) |
Constructs an empty (default-constructed) instance.
Calls MR_Matrix3f_DefaultConstruct().
| meshlib.Matrix3f.Matrix3f | ( | meshlib.Vector3f | x, |
| meshlib.Vector3f | y, | ||
| meshlib.Vector3f | z ) |
initializes matrix from its 3 rows Generated from constructor MR::Matrix3f::Matrix3f. The reference to the parameter x might be preserved in the constructed object. The reference to the parameter y might be preserved in the constructed object. The reference to the parameter z might be preserved in the constructed object.
Calls MR_Matrix3f_Construct().
| meshlib.Matrix3f.Matrix3f | ( | meshlib.Matrix3d | m | ) |
Here T == U doesn't seem to cause any issues in the C++ code, but we're still disabling it because it somehow gets emitted when generating the bindings, and results in duplicate functions in C#. Generated from constructor MR::Matrix3f::Matrix3f. The reference to the parameter m might be preserved in the constructed object.
Calls MR_Matrix3f_Construct_double().
|
static |
returns linear by angles approximation of the rotation matrix, which is close to true rotation matrix for small angles Generated from method MR::Matrix3f::approximateLinearRotationMatrixFromEuler.
Calls MR_Matrix3f_approximateLinearRotationMatrixFromEuler().
| meshlib.Vector3f meshlib.Matrix3f.col | ( | int | i | ) |
column access Generated from method MR::Matrix3f::col.
Calls MR_Matrix3f_col().
| Matrix3f meshlib.Matrix3f.copy | ( | ) |
A copy of the struct, in its own memory.
| float meshlib.Matrix3f.det | ( | ) |
computes determinant of the matrix Generated from method MR::Matrix3f::det.
Calls MR_Matrix3f_det().
|
static |
constructs a matrix from its 3 columns; use this method to get the matrix that transforms basis vectors ( plusX, plusY, plusZ ) into vectors ( x, y, z ) respectively Generated from method MR::Matrix3f::fromColumns.
Calls MR_Matrix3f_fromColumns().
|
static |
constructs a matrix from its 3 rows Generated from method MR::Matrix3f::fromRows.
Calls MR_Matrix3f_fromRows().
|
static |
Generated from method MR::Matrix3f::identity.
Calls MR_Matrix3f_identity().
| meshlib.Vector3f meshlib.Matrix3f.index | ( | int | row | ) |
row access Generated from method MR::Matrix3f::operator[].
Calls MR_Matrix3f_index().
| meshlib.Vector3f meshlib.Matrix3f.index_mut | ( | int | row | ) |
Generated from method MR::Matrix3f::operator[].
Calls MR_Matrix3f_index_mut().
| meshlib.Matrix3f meshlib.Matrix3f.inverse | ( | ) |
computes inverse matrix Generated from method MR::Matrix3f::inverse.
Calls MR_Matrix3f_inverse().
| float meshlib.Matrix3f.norm | ( | ) |
Generated from method MR::Matrix3f::norm.
Calls MR_Matrix3f_norm().
| float meshlib.Matrix3f.normSq | ( | ) |
compute sum of squared matrix elements Generated from method MR::Matrix3f::normSq.
Calls MR_Matrix3f_normSq().
| meshlib.Matrix3_float_QR meshlib.Matrix3f.qr | ( | ) |
decompose this matrix on the product Q*R, where Q is orthogonal and R is upper triangular Generated from method MR::Matrix3f::qr.
Calls MR_Matrix3f_qr().
|
static |
creates matrix representing rotation around given axis on given angle Generated from method MR::Matrix3f::rotation.
Calls MR_Matrix3f_rotation_float().
|
static |
creates matrix representing rotation that after application to (from) makes (to) vector Generated from method MR::Matrix3f::rotation.
Calls MR_Matrix3f_rotation_MR_Vector3f().
|
static |
creates matrix representing rotation from 3 Euler angles: R=R(z)*R(y)*R(x) see more https://en.wikipedia.org/wiki/Euler_angles#Conventions_by_intrinsic_rotations Generated from method MR::Matrix3f::rotationFromEuler.
Calls MR_Matrix3f_rotationFromEuler().
|
static |
returns a matrix that scales uniformly Generated from method MR::Matrix3f::scale.
Calls MR_Matrix3f_scale_1_float().
|
static |
returns a matrix that has its own scale along each axis Generated from method MR::Matrix3f::scale.
Calls MR_Matrix3f_scale_3().
|
static |
Generated from method MR::Matrix3f::scale.
Calls MR_Matrix3f_scale_1_MR_Vector3f().
| void meshlib.Matrix3f.set | ( | Matrix3f | other | ) |
Overwrites the contents with those of another struct.
| void meshlib.Matrix3f.setX | ( | meshlib.Vector3f | value | ) |
| void meshlib.Matrix3f.setY | ( | meshlib.Vector3f | value | ) |
| void meshlib.Matrix3f.setZ | ( | meshlib.Vector3f | value | ) |
| meshlib.Vector3f meshlib.Matrix3f.toEulerAngles | ( | ) |
returns 3 Euler angles, assuming this is a rotation matrix composed as follows: R=R(z)*R(y)*R(x) Generated from method MR::Matrix3f::toEulerAngles.
Calls MR_Matrix3f_toEulerAngles().
| float meshlib.Matrix3f.trace | ( | ) |
computes trace of the matrix Generated from method MR::Matrix3f::trace.
Calls MR_Matrix3f_trace().
| meshlib.Matrix3f meshlib.Matrix3f.transposed | ( | ) |
computes transposed matrix Generated from method MR::Matrix3f::transposed.
Calls MR_Matrix3f_transposed().
| meshlib.Vector3f meshlib.Matrix3f.x | ( | ) |
rows, identity matrix by default
| meshlib.Vector3f meshlib.Matrix3f.y | ( | ) |
| meshlib.Vector3f meshlib.Matrix3f.z | ( | ) |
|
static |
Generated from method MR::Matrix3f::zero.
Calls MR_Matrix3f_zero().
|
static |
The native layout of the struct.
|
static |
|
static |
|
static |
 1.14.0