|
MeshLib Java Docs
|
|
MeshLib Java Docs
|
Additional Inherited Members | |
| Protected Member Functions inherited from meshlib.CppObject | |
| CppObject (java.lang.foreign.MemorySegment ptr, java.util.function.Consumer< java.lang.foreign.MemorySegment > destroy, java.lang.Object owner) | |
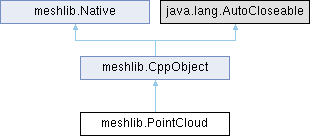
Generated from class MR::PointCloud.
Instances created here own their C++ objects, see CppObject.
| meshlib.PointCloud.PointCloud | ( | java.lang.foreign.MemorySegment | ptr, |
| boolean | owned, | ||
| java.lang.Object | owner ) |
Wraps a pointer from the C bindings. If owned, the object is destroyed when the wrapper dies. owner is kept alive as long as this wrapper is. Not for normal use.
| meshlib.PointCloud.PointCloud | ( | ) |
Constructs an empty (default-constructed) instance.
Calls MR_PointCloud_DefaultConstruct().
| meshlib.PointCloud.PointCloud | ( | meshlib.PointCloud | _other | ) |
Generated from constructor MR::PointCloud::PointCloud. The reference to things referred to by the parameter _other (if any) might be preserved in the constructed object.
Calls MR_PointCloud_ConstructFromAnother().
| void meshlib.PointCloud.addPartByMask | ( | meshlib.PointCloud | from, |
| meshlib.VertBitSet | fromVerts, | ||
| meshlib.CloudPartMapping | outMap, | ||
| meshlib.VertCoords | extNormals ) |
appends points (and normals if it possible) (from) in addition to this points if this obj have normals and from obj has not it then don't do anything
| extNormals | if given then they will be copied instead of from.normals Generated from method MR::PointCloud::addPartByMask. |
Calls MR_PointCloud_addPartByMask().
| meshlib.VertId meshlib.PointCloud.addPoint | ( | meshlib.Vector3f | point | ) |
appends a point and returns its VertId Generated from method MR::PointCloud::addPoint.
Calls MR_PointCloud_addPoint().
| meshlib.VertId meshlib.PointCloud.addPoint | ( | meshlib.Vector3f | point, |
| meshlib.Vector3f | normal ) |
appends a point with normal and returns its VertId Generated from method MR::PointCloud::addPoint.
Calls MR_PointCloud_addPoint_normal().
| meshlib.PointCloud meshlib.PointCloud.assignFromAnother | ( | meshlib.PointCloud | _other | ) |
Generated from method MR::PointCloud::operator=. The reference to things referred to by the parameter _other (if any) might be preserved in this object.
Calls MR_PointCloud_AssignFromAnother().
| long meshlib.PointCloud.calcNumValidPoints | ( | ) |
computes the total number of valid points in the cloud Generated from method MR::PointCloud::calcNumValidPoints.
Calls MR_PointCloud_calcNumValidPoints().
| meshlib.Box3f meshlib.PointCloud.computeBoundingBox | ( | meshlib.AffineXf3f | toWorld | ) |
passes through all valid points and finds the minimal bounding box containing all of them; if toWorld transformation is given then returns minimal bounding box in world space Generated from method MR::PointCloud::computeBoundingBox.
Calls MR_PointCloud_computeBoundingBox().
| meshlib.Box3f meshlib.PointCloud.computeBoundingBox | ( | meshlib.VertBitSet | region, |
| meshlib.AffineXf3f | toWorld ) |
passes through all given vertices (or all valid vertices if region == null) and finds the minimal bounding box containing all of them if toWorld transformation is given then returns minimal bounding box in world space Generated from method MR::PointCloud::computeBoundingBox.
Calls MR_PointCloud_computeBoundingBox_region().
| meshlib.Vector3f meshlib.PointCloud.findCenterFromBBox | ( | ) |
computes bounding box and returns its center Generated from method MR::PointCloud::findCenterFromBBox.
Calls MR_PointCloud_findCenterFromBBox().
| meshlib.Vector3f meshlib.PointCloud.findCenterFromPoints | ( | ) |
computes average position of all valid points Generated from method MR::PointCloud::findCenterFromPoints.
Calls MR_PointCloud_findCenterFromPoints().
| void meshlib.PointCloud.flipOrientation | ( | meshlib.VertBitSet | region | ) |
flip orientation (normals) of given points (or all valid points is nullptr) Generated from method MR::PointCloud::flipOrientation.
Calls MR_PointCloud_flipOrientation().
| meshlib.AABBTreePoints meshlib.PointCloud.getAABBTree | ( | ) |
returns cached aabb-tree for this point cloud, creating it if it did not exist in a thread-safe manner Generated from method MR::PointCloud::getAABBTree.
Calls MR_PointCloud_getAABBTree().
| meshlib.AABBTreePoints meshlib.PointCloud.getAABBTreeNotCreate | ( | ) |
returns cached aabb-tree for this point cloud, but does not create it if it did not exist Generated from method MR::PointCloud::getAABBTreeNotCreate.
Calls MR_PointCloud_getAABBTreeNotCreate().
| meshlib.Box3f meshlib.PointCloud.getBoundingBox | ( | ) |
returns the minimal bounding box containing all valid vertices (implemented via getAABBTree()) Generated from method MR::PointCloud::getBoundingBox.
Calls MR_PointCloud_getBoundingBox().
| meshlib.std_vector_MR_VertId meshlib.PointCloud.getLexicographicalOrder | ( | ) |
returns all valid point ids sorted lexicographically by their coordinates (optimal for uniform sampling) Generated from method MR::PointCloud::getLexicographicalOrder.
Calls MR_PointCloud_getLexicographicalOrder().
| meshlib.VertBitSet meshlib.PointCloud.getVertIds | ( | meshlib.VertBitSet | region | ) |
if region pointer is not null then converts it in reference, otherwise returns all valid points in the cloud Generated from method MR::PointCloud::getVertIds.
Calls MR_PointCloud_getVertIds().
| boolean meshlib.PointCloud.hasNormals | ( | ) |
returns true if there is a normal for each point Generated from method MR::PointCloud::hasNormals.
Calls MR_PointCloud_hasNormals().
| long meshlib.PointCloud.heapBytes | ( | ) |
returns the amount of memory this object occupies on heap Generated from method MR::PointCloud::heapBytes.
Calls MR_PointCloud_heapBytes().
| void meshlib.PointCloud.invalidateCaches | ( | ) |
Invalidates caches (e.g. aabb-tree) after a change in point cloud Generated from method MR::PointCloud::invalidateCaches.
Calls MR_PointCloud_invalidateCaches().
| void meshlib.PointCloud.mirror | ( | meshlib.Plane3f | plane | ) |
reflects the points from a given plane Generated from method MR::PointCloud::mirror.
Calls MR_PointCloud_mirror().
| meshlib.VertCoords meshlib.PointCloud.normals | ( | ) |
unit normal directions of points (can be empty if no normals are known) Returns a pointer to a member variable of class MR::PointCloud named normals. The reference to this object might be preserved as the return value.
Calls MR_PointCloud_Get_normals().
| meshlib.VertBMap meshlib.PointCloud.pack | ( | meshlib.Reorder | reoder | ) |
tightly packs all arrays eliminating invalid points, reorders valid points according to given strategy;
Calls MR_PointCloud_pack_MR_Reorder().
| boolean meshlib.PointCloud.pack | ( | meshlib.VertMap | outNew2Old | ) |
tightly packs all arrays eliminating invalid points, but relative order of valid points is preserved; returns false if the cloud was packed before the call and nothing has been changed; if pack is done optionally returns mappings: new.id -> old.id Generated from method MR::PointCloud::pack.
Calls MR_PointCloud_pack_MR_VertMap_ptr().
| meshlib.VertCoords meshlib.PointCloud.points | ( | ) |
coordinates of points Returns a pointer to a member variable of class MR::PointCloud named points. The reference to this object might be preserved as the return value.
Calls MR_PointCloud_Get_points().
| void meshlib.PointCloud.setNormals | ( | meshlib.VertCoords | value | ) |
unit normal directions of points (can be empty if no normals are known) Modifies a member variable of class MR::PointCloud named normals. The reference to the parameter value might be preserved in this object in element normals.
Calls MR_PointCloud_Set_normals().
| void meshlib.PointCloud.setPoints | ( | meshlib.VertCoords | value | ) |
coordinates of points Modifies a member variable of class MR::PointCloud named points. The reference to the parameter value might be preserved in this object in element points.
Calls MR_PointCloud_Set_points().
| void meshlib.PointCloud.setValidPoints | ( | meshlib.VertBitSet | value | ) |
only points and normals corresponding to set bits here are valid Modifies a member variable of class MR::PointCloud named validPoints. The reference to the parameter value might be preserved in this object in element validPoints.
Calls MR_PointCloud_Set_validPoints().
| void meshlib.PointCloud.transform | ( | meshlib.AffineXf3f | xf, |
| meshlib.VertBitSet | region ) |
applies given transformation to specified points and corresponding transformation to their normals if present; if region is nullptr, all valid points are modified Generated from method MR::PointCloud::transform.
Calls MR_PointCloud_transform().
| void meshlib.PointCloud.updateCaches | ( | meshlib.VertBitSet | changedVerts | ) |
updates existing caches in case of few points were changed insignificantly, and validPoints remained unchanged; it shall be considered as a faster alternative to invalidateCaches() and following rebuild of trees
| changedVerts | points with modified coordinates, nullptr means all valid points Generated from method MR::PointCloud::updateCaches. |
Calls MR_PointCloud_updateCaches().
| meshlib.VertBitSet meshlib.PointCloud.validPoints | ( | ) |
only points and normals corresponding to set bits here are valid Returns a pointer to a member variable of class MR::PointCloud named validPoints. The reference to this object might be preserved as the return value.
Calls MR_PointCloud_Get_validPoints().
 1.14.0