|
MeshLib Rust Docs
|
|
MeshLib Rust Docs
|
Static Public Member Functions | |
| static auto | new () -> meshlib::Box2d |
| static auto | construct_2 (min:&meshlib::Vector2d, max:&meshlib::Vector2d) -> meshlib::Box2d |
| static auto | construct_1 (_1:&meshlib::NoInit) -> meshlib::Box2d |
| static auto | from_min_and_size (min:&meshlib::Vector2d, size:&meshlib::Vector2d) -> meshlib::Box2d |
| static auto | get_min_box_corner (n:&meshlib::Vector2d) -> meshlib::Vector2b |
| static auto | get_max_box_corner (n:&meshlib::Vector2d) -> meshlib::Vector2b |
| static auto | elements () -> *const core::ffi::c_int |
Public Attributes | |
| meshlib::Vector2d | min |
| meshlib::Vector2d | max |
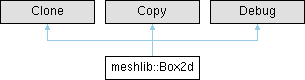
Box given by its min- and max- corners Generated from class MR::Box2d.
Generated from struct MR::Box2d. The fields are accessed directly.
| auto meshlib::Box2d::center | ( | ) | const -> meshlib::Vector2d |
computes center of the box Generated from method MR::Box2d::center.
Calls MR_Box2d_center().
|
static |
If the compiler supports requires, use that instead of std::enable_if here. Not (only) because it looks cooler, but because of a bug in our binding generator that makes it choke on it: https://github.com/MeshInspector/mrbind/issues/19 Generated from constructor MR::Box2d::Box2d.
Calls MR_Box2d_Construct_1(). The reference to the parameter _1 might be preserved in the constructed object.
|
static |
Generated from constructor MR::Box2d::Box2d.
Calls MR_Box2d_Construct_2(). The reference to the parameter min might be preserved in the constructed object. The reference to the parameter max might be preserved in the constructed object.
| auto meshlib::Box2d::contains_mr_box2d | ( | otherbox:&meshlib::Box2d | ) | const -> bool |
checks whether given box is fully inside (the surfaces may touch) of this box Generated from method MR::Box2d::contains.
Calls MR_Box2d_contains_MR_Box2d().
| auto meshlib::Box2d::contains_mr_vector2d | ( | pt:&meshlib::Vector2d | ) | const -> bool |
checks whether given point is inside (including the surface) of this box Generated from method MR::Box2d::contains.
Calls MR_Box2d_contains_MR_Vector2d().
| auto meshlib::Box2d::corner | ( | c:&meshlib::Vector2b | ) | const -> meshlib::Vector2d |
returns the corner of this box as specified by given bool-vector: 0 element in (c) means take min's coordinate, 1 element in (c) means take max's coordinate Generated from method MR::Box2d::corner.
Calls MR_Box2d_corner().
| auto meshlib::Box2d::diagonal | ( | ) | const -> f64 |
computes length from min to max Generated from method MR::Box2d::diagonal.
Calls MR_Box2d_diagonal().
|
static |
Returns a pointer to a member variable of class MR::Box2d named elements.
Calls MR_Box2d_Get_elements().
| auto meshlib::Box2d::expanded | ( | expansion:&meshlib::Vector2d | ) | const -> meshlib::Box2d |
decreases min and increased max on given value Generated from method MR::Box2d::expanded.
Calls MR_Box2d_expanded().
|
static |
Generated from method MR::Box2d::fromMinAndSize.
Calls MR_Box2d_fromMinAndSize().
| auto meshlib::Box2d::get_box_closest_point_to | ( | pt:&meshlib::Vector2d | ) | const -> meshlib::Vector2d |
returns closest point in the box to given point Generated from method MR::Box2d::getBoxClosestPointTo.
Calls MR_Box2d_getBoxClosestPointTo().
| auto meshlib::Box2d::get_distance_sq_mr_box2d | ( | b:&meshlib::Box2d | ) | const -> f64 |
returns squared distance between this box and given one; returns zero if the boxes touch or intersect Generated from method MR::Box2d::getDistanceSq.
Calls MR_Box2d_getDistanceSq_MR_Box2d().
| auto meshlib::Box2d::get_distance_sq_mr_vector2d | ( | pt:&meshlib::Vector2d | ) | const -> f64 |
returns squared distance between this box and given point; returns zero if the point is inside or on the boundary of the box Generated from method MR::Box2d::getDistanceSq.
Calls MR_Box2d_getDistanceSq_MR_Vector2d().
|
static |
considering all planes with given normal and arbitrary shift: dot(n,x) = d finds the box's corner for which d is maximal Generated from method MR::Box2d::getMaxBoxCorner.
Calls MR_Box2d_getMaxBoxCorner().
|
static |
considering all planes with given normal and arbitrary shift: dot(n,x) = d finds the box's corner for which d is minimal Generated from method MR::Box2d::getMinBoxCorner.
Calls MR_Box2d_getMinBoxCorner().
| auto meshlib::Box2d::get_projection | ( | pt:&meshlib::Vector2d | ) | const -> meshlib::Vector2d |
returns the closest point on the box to the given point for points outside the box this is equivalent to getBoxClosestPointTo Generated from method MR::Box2d::getProjection.
Calls MR_Box2d_getProjection().
| void meshlib::Box2d::include_mr_box2d | ( | b:&meshlib::Box2d | ) |
minimally increases the box to include another box Generated from method MR::Box2d::include.
Calls MR_Box2d_include_MR_Box2d().
| void meshlib::Box2d::include_mr_vector2d | ( | pt:&meshlib::Vector2d | ) |
minimally increases the box to include given point Generated from method MR::Box2d::include.
Calls MR_Box2d_include_MR_Vector2d().
| auto meshlib::Box2d::index | ( | e:core::ffi::c_int | ) | const -> &meshlib::Vector2d |
min/max access by 0/1 index Generated from method MR::Box2d::operator[].
Calls MR_Box2d_index().
| auto meshlib::Box2d::index_mut | ( | e:core::ffi::c_int | ) | -> &mut meshlib::Vector2d |
Generated from method MR::Box2d::operator[].
Calls MR_Box2d_index_mut().
| auto meshlib::Box2d::insignificantly_expanded | ( | ) | const -> meshlib::Box2d |
decreases min and increases max to their closest representable value Generated from method MR::Box2d::insignificantlyExpanded.
Calls MR_Box2d_insignificantlyExpanded().
| auto meshlib::Box2d::intersect | ( | b:&meshlib::Box2d | ) | -> &mut meshlib::Box2d |
Generated from method MR::Box2d::intersect.
Calls MR_Box2d_intersect().
| auto meshlib::Box2d::intersection | ( | b:&meshlib::Box2d | ) | const -> meshlib::Box2d |
computes intersection between this and other box Generated from method MR::Box2d::intersection.
Calls MR_Box2d_intersection().
| auto meshlib::Box2d::intersects | ( | b:&meshlib::Box2d | ) | const -> bool |
checks whether this box intersects or touches given box Generated from method MR::Box2d::intersects.
Calls MR_Box2d_intersects().
|
static |
create invalid box by default
Calls MR_Box2d_DefaultConstruct().
| auto meshlib::Box2d::op_equal | ( | a:&meshlib::Box2d | ) | const -> bool |
Generated from method MR::Box2d::operator==.
Calls MR_equal_MR_Box2d().
| auto meshlib::Box2d::op_not_equal | ( | a:&meshlib::Box2d | ) | const -> bool |
Generated from method MR::Box2d::operator!=.
Calls MR_not_equal_MR_Box2d().
| auto meshlib::Box2d::size | ( | ) | const -> meshlib::Vector2d |
computes size of the box in all dimensions Generated from method MR::Box2d::size.
Calls MR_Box2d_size().
| auto meshlib::Box2d::valid | ( | ) | const -> bool |
true if the box contains at least one point Generated from method MR::Box2d::valid.
Calls MR_Box2d_valid().
| auto meshlib::Box2d::volume | ( | ) | const -> f64 |
computes the volume of this box Generated from method MR::Box2d::volume.
Calls MR_Box2d_volume().
| meshlib::Vector2d meshlib::Box2d::max |
| meshlib::Vector2d meshlib::Box2d::min |
 1.14.0