|
MeshLib Rust Docs
|
|
MeshLib Rust Docs
|
Public Member Functions | |
| auto | assign_from_another (_other:&meshlib::CameraPointsTriangulationSettings) -> &mut meshlib::CameraPointsTriangulationSettings |
| auto | intrinsics () const -> &meshlib::Matrix3f |
| auto | intrinsics_mut () -> &mut meshlib::Matrix3f |
| void | set_intrinsics (value:meshlib::Matrix3f) |
| auto | weld_pixels () const -> &f32 |
| auto | weld_pixels_mut () -> &mut f32 |
| void | set_weld_pixels (value:f32) |
| auto | out_smallest_map () const -> *const *mut meshlib::ffi::MR_VertMap |
| auto | out_smallest_map_mut () -> *mut *mut meshlib::ffi::MR_VertMap |
| void | set_out_smallest_map (value:Option<&mut meshlib::VertMap >) |
| auto | out_projected_points () const -> *const *mut meshlib::ffi::MR_VertCoords |
| auto | out_projected_points_mut () -> *mut *mut meshlib::ffi::MR_VertCoords |
| void | set_out_projected_points (value:Option<&mut meshlib::VertCoords >) |
Static Public Member Functions | |
| static auto | new () -> meshlib::Owned< meshlib::CameraPointsTriangulationSettings > |
| static auto | construct_from (intrinsics:meshlib::Matrix3f, weldPixels:f32, outSmallestMap:Option<&mut meshlib::VertMap >, outProjectedPoints:Option<&mut meshlib::VertCoords >) -> meshlib::Owned< meshlib::CameraPointsTriangulationSettings > |
| static auto | construct_from_another (_other:&meshlib::CameraPointsTriangulationSettings) -> meshlib::Owned< meshlib::CameraPointsTriangulationSettings > |
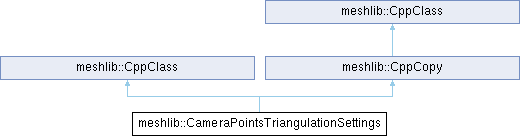
| Static Public Member Functions inherited from meshlib::CppClass | |
| static void | destroy (ptr:*mut Self) |
| Static Public Member Functions inherited from meshlib::CppCopy | |
| static auto | copy (ptr:*const Self) -> *mut Self |
Generated from class MR::CameraPointsTriangulationSettings.
Generated from class MR::CameraPointsTriangulationSettings. Heap-allocated instances are held in Owned<CameraPointsTriangulationSettings>.
| auto meshlib::CameraPointsTriangulationSettings::assign_from_another | ( | _other:&meshlib::CameraPointsTriangulationSettings | ) | -> &mut meshlib::CameraPointsTriangulationSettings |
Generated from method MR::CameraPointsTriangulationSettings::operator=.
Calls MR_CameraPointsTriangulationSettings_AssignFromAnother(). The reference to things referred to by the parameter _other (if any) might be preserved in this object.
|
static |
Constructs MR::CameraPointsTriangulationSettings elementwise.
Calls MR_CameraPointsTriangulationSettings_ConstructFrom(). The reference to the parameter intrinsics might be preserved in the constructed object. The reference to the parameter outSmallestMap might be preserved in the constructed object. The reference to the parameter outProjectedPoints might be preserved in the constructed object.
|
static |
Generated from constructor MR::CameraPointsTriangulationSettings::CameraPointsTriangulationSettings.
Calls MR_CameraPointsTriangulationSettings_ConstructFromAnother(). The reference to things referred to by the parameter _other (if any) might be preserved in the constructed object.
| auto meshlib::CameraPointsTriangulationSettings::intrinsics | ( | ) | const -> &meshlib::Matrix3f |
camera intrinsic matrix: the image-plane (pixel) position of a point p in camera space is ( K * p ).xy / ( K * p ).z Returns a pointer to a member variable of class MR::CameraPointsTriangulationSettings named intrinsics.
Calls MR_CameraPointsTriangulationSettings_Get_intrinsics(). The reference to this object might be preserved as the return value.
| auto meshlib::CameraPointsTriangulationSettings::intrinsics_mut | ( | ) | -> &mut meshlib::Matrix3f |
camera intrinsic matrix: the image-plane (pixel) position of a point p in camera space is ( K * p ).xy / ( K * p ).z Returns a mutable pointer to a member variable of class MR::CameraPointsTriangulationSettings named intrinsics.
Calls MR_CameraPointsTriangulationSettings_GetMutable_intrinsics(). The reference to this object might be preserved as the return value.
|
static |
Constructs an empty (default-constructed) instance.
Calls MR_CameraPointsTriangulationSettings_DefaultConstruct().
| auto meshlib::CameraPointsTriangulationSettings::out_projected_points | ( | ) | const -> *const *mut meshlib::ffi::MR_VertCoords |
if not null, receives the image-plane coordinates of all points as ( x, -y, 1 ) with y mirrored, for welded points these are the coordinates of the averaged position, for invalid cloud points zeros Returns a pointer to a member variable of class MR::CameraPointsTriangulationSettings named outProjectedPoints.
Calls MR_CameraPointsTriangulationSettings_Get_outProjectedPoints(). Some types are raw C types, see the C bindings for the details. The reference to this object might be preserved as the return value.
| auto meshlib::CameraPointsTriangulationSettings::out_projected_points_mut | ( | ) | -> *mut *mut meshlib::ffi::MR_VertCoords |
if not null, receives the image-plane coordinates of all points as ( x, -y, 1 ) with y mirrored, for welded points these are the coordinates of the averaged position, for invalid cloud points zeros Returns a mutable pointer to a member variable of class MR::CameraPointsTriangulationSettings named outProjectedPoints.
Calls MR_CameraPointsTriangulationSettings_GetMutable_outProjectedPoints(). Some types are raw C types, see the C bindings for the details. The reference to this object might be preserved as the return value.
| auto meshlib::CameraPointsTriangulationSettings::out_smallest_map | ( | ) | const -> *const *mut meshlib::ffi::MR_VertMap |
if not null, receives the result of findSmallestCloseVertices on the image-plane positions: each point is mapped to the point it was merged into (or to itself); left unchanged if weldPixels <= 0 Returns a pointer to a member variable of class MR::CameraPointsTriangulationSettings named outSmallestMap.
Calls MR_CameraPointsTriangulationSettings_Get_outSmallestMap(). Some types are raw C types, see the C bindings for the details. The reference to this object might be preserved as the return value.
| auto meshlib::CameraPointsTriangulationSettings::out_smallest_map_mut | ( | ) | -> *mut *mut meshlib::ffi::MR_VertMap |
if not null, receives the result of findSmallestCloseVertices on the image-plane positions: each point is mapped to the point it was merged into (or to itself); left unchanged if weldPixels <= 0 Returns a mutable pointer to a member variable of class MR::CameraPointsTriangulationSettings named outSmallestMap.
Calls MR_CameraPointsTriangulationSettings_GetMutable_outSmallestMap(). Some types are raw C types, see the C bindings for the details. The reference to this object might be preserved as the return value.
| void meshlib::CameraPointsTriangulationSettings::set_intrinsics | ( | value:meshlib::Matrix3f | ) |
camera intrinsic matrix: the image-plane (pixel) position of a point p in camera space is ( K * p ).xy / ( K * p ).z Modifies a member variable of class MR::CameraPointsTriangulationSettings named intrinsics.
Calls MR_CameraPointsTriangulationSettings_Set_intrinsics(). The reference to the parameter value might be preserved in this object in element intrinsics.
| void meshlib::CameraPointsTriangulationSettings::set_out_projected_points | ( | value:Option<&mut meshlib::VertCoords > | ) |
if not null, receives the image-plane coordinates of all points as ( x, -y, 1 ) with y mirrored, for welded points these are the coordinates of the averaged position, for invalid cloud points zeros Modifies a member variable of class MR::CameraPointsTriangulationSettings named outProjectedPoints.
Calls MR_CameraPointsTriangulationSettings_Set_outProjectedPoints(). The reference to the parameter value might be preserved in this object in element outProjectedPoints.
| void meshlib::CameraPointsTriangulationSettings::set_out_smallest_map | ( | value:Option<&mut meshlib::VertMap > | ) |
if not null, receives the result of findSmallestCloseVertices on the image-plane positions: each point is mapped to the point it was merged into (or to itself); left unchanged if weldPixels <= 0 Modifies a member variable of class MR::CameraPointsTriangulationSettings named outSmallestMap.
Calls MR_CameraPointsTriangulationSettings_Set_outSmallestMap(). The reference to the parameter value might be preserved in this object in element outSmallestMap.
| void meshlib::CameraPointsTriangulationSettings::set_weld_pixels | ( | value:f32 | ) |
points closer than this distance in the image plane are merged into one vertex located at their average position; non-positive value disables merging Modifies a member variable of class MR::CameraPointsTriangulationSettings named weldPixels.
Calls MR_CameraPointsTriangulationSettings_Set_weldPixels().
| auto meshlib::CameraPointsTriangulationSettings::weld_pixels | ( | ) | const -> &f32 |
points closer than this distance in the image plane are merged into one vertex located at their average position; non-positive value disables merging Returns a pointer to a member variable of class MR::CameraPointsTriangulationSettings named weldPixels.
Calls MR_CameraPointsTriangulationSettings_Get_weldPixels(). The reference to this object might be preserved as the return value.
| auto meshlib::CameraPointsTriangulationSettings::weld_pixels_mut | ( | ) | -> &mut f32 |
points closer than this distance in the image plane are merged into one vertex located at their average position; non-positive value disables merging Returns a mutable pointer to a member variable of class MR::CameraPointsTriangulationSettings named weldPixels.
Calls MR_CameraPointsTriangulationSettings_GetMutable_weldPixels(). The reference to this object might be preserved as the return value.
 1.14.0