|
MeshLib Rust Docs
|
|
MeshLib Rust Docs
|
Public Member Functions | |
| auto | set_point_cloud (pointCloud:&meshlib::PointCloud) -> meshlib::Owned< meshlib::expected_void_std_string > |
| auto | find_projections (results:&mut meshlib::std_vector_MR_PointsProjectionResult, points:&meshlib::VertCoords, settings:&meshlib::FindProjectionOnPointsSettings) const -> meshlib::Owned< meshlib::expected_void_std_string > |
| auto | projections_heap_bytes (numProjections:usize) const -> usize |
Additional Inherited Members | |
| Static Public Member Functions inherited from meshlib::CppClass | |
| static void | destroy (ptr:*mut Self) |
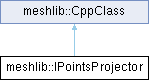
abstract class for computing the closest points of point clouds Generated from class MR::IPointsProjector. Derived classes: Direct: (non-virtual) MR::Cuda::PointsProjector MR::PointsProjector
Generated from class MR::IPointsProjector. Heap-allocated instances are held in Owned<IPointsProjector>.
| auto meshlib::IPointsProjector::find_projections | ( | results:&mut meshlib::std_vector_MR_PointsProjectionResult | , |
| points:&meshlib::VertCoords | , | ||
| settings:&meshlib::FindProjectionOnPointsSettings | ) const -> meshlib::Owned< meshlib::expected_void_std_string > |
computes the closest points on point cloud to given points Generated from method MR::IPointsProjector::findProjections.
Calls MR_IPointsProjector_findProjections().
| auto meshlib::IPointsProjector::projections_heap_bytes | ( | numProjections:usize | ) | const -> usize |
Returns amount of memory needed to compute projections Generated from method MR::IPointsProjector::projectionsHeapBytes.
Calls MR_IPointsProjector_projectionsHeapBytes().
| auto meshlib::IPointsProjector::set_point_cloud | ( | pointCloud:&meshlib::PointCloud | ) | -> meshlib::Owned< meshlib::expected_void_std_string > |
sets the reference point cloud Generated from method MR::IPointsProjector::setPointCloud.
Calls MR_IPointsProjector_setPointCloud().
 1.14.0