|
MeshLib Rust Docs
|
|
MeshLib Rust Docs
|
Public Member Functions | |
| auto | assign_from_another (_other:&meshlib::PointToPointAligningTransform) -> &mut meshlib::PointToPointAligningTransform |
| void | add_3_mr_vector3d (p1:&meshlib::Vector3d, p2:&meshlib::Vector3d, w:Option< f64 >) |
| void | add_3_mr_vector3f (p1:&meshlib::Vector3f, p2:&meshlib::Vector3f, w:Option< f32 >) |
| void | add_1 (other:&meshlib::PointToPointAligningTransform) |
| void | clear () |
| auto | centroid1 () const -> meshlib::Vector3d |
| auto | centroid2 () const -> meshlib::Vector3d |
| auto | total_weight () const -> f64 |
| auto | find_best_rigid_xf () const -> meshlib::AffineXf3d |
| auto | find_best_rigid_scale_xf () const -> meshlib::AffineXf3d |
| auto | find_best_rigid_xf_fixed_rotation_axis (axis:&meshlib::Vector3d) const -> meshlib::AffineXf3d |
| auto | find_best_rigid_xf_orthogonal_rotation_axis (ort:&meshlib::Vector3d) const -> meshlib::AffineXf3d |
| auto | find_best_translation () const -> meshlib::Vector3d |
Static Public Member Functions | |
| static auto | new () -> meshlib::Owned< meshlib::PointToPointAligningTransform > |
| static auto | construct_from_another (_other:&meshlib::PointToPointAligningTransform) -> meshlib::Owned< meshlib::PointToPointAligningTransform > |
| Static Public Member Functions inherited from meshlib::CppClass | |
| static void | destroy (ptr:*mut Self) |
| Static Public Member Functions inherited from meshlib::CppCopy | |
| static auto | copy (ptr:*const Self) -> *mut Self |
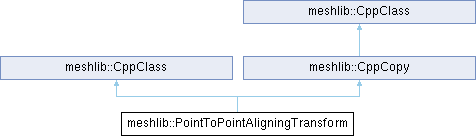
This class and its main method can be used to solve the problem well-known as the absolute orientation problem. It means computing the transformation that aligns two sets of points for which correspondence is known. Generated from class MR::PointToPointAligningTransform.
Generated from class MR::PointToPointAligningTransform. Heap-allocated instances are held in Owned<PointToPointAligningTransform>.
| void meshlib::PointToPointAligningTransform::add_1 | ( | other:&meshlib::PointToPointAligningTransform | ) |
Add another two sets of points. Generated from method MR::PointToPointAligningTransform::add.
Calls MR_PointToPointAligningTransform_add_1().
| void meshlib::PointToPointAligningTransform::add_3_mr_vector3d | ( | p1:&meshlib::Vector3d | , |
| p2:&meshlib::Vector3d | , | ||
| w:Option< f64 > | ) |
Add one pair of points in the set Generated from method MR::PointToPointAligningTransform::add.
Calls MR_PointToPointAligningTransform_add_3_MR_Vector3d().
| void meshlib::PointToPointAligningTransform::add_3_mr_vector3f | ( | p1:&meshlib::Vector3f | , |
| p2:&meshlib::Vector3f | , | ||
| w:Option< f32 > | ) |
Add one pair of points in the set Generated from method MR::PointToPointAligningTransform::add.
Calls MR_PointToPointAligningTransform_add_3_MR_Vector3f().
| auto meshlib::PointToPointAligningTransform::assign_from_another | ( | _other:&meshlib::PointToPointAligningTransform | ) | -> &mut meshlib::PointToPointAligningTransform |
Generated from method MR::PointToPointAligningTransform::operator=.
Calls MR_PointToPointAligningTransform_AssignFromAnother(). The reference to things referred to by the parameter _other (if any) might be preserved in this object.
| auto meshlib::PointToPointAligningTransform::centroid1 | ( | ) | const -> meshlib::Vector3d |
returns weighted centroid of points p1 accumulated so far Generated from method MR::PointToPointAligningTransform::centroid1.
Calls MR_PointToPointAligningTransform_centroid1().
| auto meshlib::PointToPointAligningTransform::centroid2 | ( | ) | const -> meshlib::Vector3d |
returns weighted centroid of points p2 accumulated so far Generated from method MR::PointToPointAligningTransform::centroid2.
Calls MR_PointToPointAligningTransform_centroid2().
| void meshlib::PointToPointAligningTransform::clear | ( | ) |
Clear sets. Generated from method MR::PointToPointAligningTransform::clear.
Calls MR_PointToPointAligningTransform_clear().
|
static |
Generated from constructor MR::PointToPointAligningTransform::PointToPointAligningTransform.
Calls MR_PointToPointAligningTransform_ConstructFromAnother(). The reference to things referred to by the parameter _other (if any) might be preserved in the constructed object.
| auto meshlib::PointToPointAligningTransform::find_best_rigid_scale_xf | ( | ) | const -> meshlib::AffineXf3d |
this version searches for best rigid body transformation with uniform scaling Generated from method MR::PointToPointAligningTransform::findBestRigidScaleXf.
Calls MR_PointToPointAligningTransform_findBestRigidScaleXf().
| auto meshlib::PointToPointAligningTransform::find_best_rigid_xf | ( | ) | const -> meshlib::AffineXf3d |
Compute transformation as the solution to a least squares formulation of the problem: xf( p1_i ) = p2_i this version searches for best rigid body transformation Generated from method MR::PointToPointAligningTransform::findBestRigidXf.
Calls MR_PointToPointAligningTransform_findBestRigidXf().
| auto meshlib::PointToPointAligningTransform::find_best_rigid_xf_fixed_rotation_axis | ( | axis:&meshlib::Vector3d | ) | const -> meshlib::AffineXf3d |
this version searches for best transformation where rotation is allowed only around given axis and with arbitrary translation Generated from method MR::PointToPointAligningTransform::findBestRigidXfFixedRotationAxis.
Calls MR_PointToPointAligningTransform_findBestRigidXfFixedRotationAxis().
| auto meshlib::PointToPointAligningTransform::find_best_rigid_xf_orthogonal_rotation_axis | ( | ort:&meshlib::Vector3d | ) | const -> meshlib::AffineXf3d |
this version searches for best transformation where rotation is allowed only around axes orthogonal to given one Generated from method MR::PointToPointAligningTransform::findBestRigidXfOrthogonalRotationAxis.
Calls MR_PointToPointAligningTransform_findBestRigidXfOrthogonalRotationAxis().
| auto meshlib::PointToPointAligningTransform::find_best_translation | ( | ) | const -> meshlib::Vector3d |
Simplified solution for translational part only Generated from method MR::PointToPointAligningTransform::findBestTranslation.
Calls MR_PointToPointAligningTransform_findBestTranslation().
|
static |
Constructs an empty (default-constructed) instance.
Calls MR_PointToPointAligningTransform_DefaultConstruct().
| auto meshlib::PointToPointAligningTransform::total_weight | ( | ) | const -> f64 |
returns summed weight of points accumulated so far Generated from method MR::PointToPointAligningTransform::totalWeight.
Calls MR_PointToPointAligningTransform_totalWeight().
 1.14.0