|
MeshLib Rust Docs
|
|
MeshLib Rust Docs
|
Public Member Functions | |
| auto | convert_to_mr_matrix3d () const -> meshlib::Matrix3d |
| auto | assign_from_another (_other:&meshlib::Quaterniond) -> &mut meshlib::Quaterniond |
| auto | im () const -> meshlib::Vector3d |
| auto | angle () const -> f64 |
| auto | axis () const -> meshlib::Vector3d |
| auto | norm_sq () const -> f64 |
| auto | norm () const -> f64 |
| auto | op_neg () const -> meshlib::Owned< meshlib::Quaterniond > |
| void | normalize () |
| auto | normalized () const -> meshlib::Owned< meshlib::Quaterniond > |
| auto | conjugate () const -> meshlib::Owned< meshlib::Quaterniond > |
| auto | inverse () const -> meshlib::Owned< meshlib::Quaterniond > |
| auto | call (p:&meshlib::Vector3d) const -> meshlib::Vector3d |
| auto | mul_assign (s:f64) -> &mut meshlib::Quaterniond |
| auto | div_assign (s:f64) -> &mut meshlib::Quaterniond |
| auto | a () const -> &f64 |
| auto | a_mut () -> &mut f64 |
| void | set_a (value:f64) |
| auto | b () const -> &f64 |
| auto | b_mut () -> &mut f64 |
| void | set_b (value:f64) |
| auto | c () const -> &f64 |
| auto | c_mut () -> &mut f64 |
| void | set_c (value:f64) |
| auto | d () const -> &f64 |
| auto | d_mut () -> &mut f64 |
| void | set_d (value:f64) |
Related Symbols | |
(Note that these are not member symbols.) | |
| static auto | construct_2_const_mr_vector3d_ref_double (axis:&meshlib::Vector3d, angle:f64) -> meshlib::Owned< meshlib::Quaterniond > |
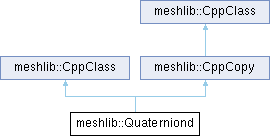
Represents a quaternion following the notations from https://en.wikipedia.org/wiki/Quaternion Generated from class MR::Quaterniond.
Generated from class MR::Quaterniond. Heap-allocated instances are held in Owned<Quaterniond>.
| auto meshlib::Quaterniond::a | ( | ) | const -> &f64 |
< real part of the quaternion Returns a pointer to a member variable of class MR::Quaterniond named a.
Calls MR_Quaterniond_Get_a(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::a_mut | ( | ) | -> &mut f64 |
< real part of the quaternion Returns a mutable pointer to a member variable of class MR::Quaterniond named a.
Calls MR_Quaterniond_GetMutable_a(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::angle | ( | ) | const -> f64 |
returns angle of rotation encoded in this quaternion Generated from method MR::Quaterniond::angle.
Calls MR_Quaterniond_angle().
| auto meshlib::Quaterniond::assign_from_another | ( | _other:&meshlib::Quaterniond | ) | -> &mut meshlib::Quaterniond |
Generated from method MR::Quaterniond::operator=.
Calls MR_Quaterniond_AssignFromAnother(). The reference to things referred to by the parameter _other (if any) might be preserved in this object.
| auto meshlib::Quaterniond::axis | ( | ) | const -> meshlib::Vector3d |
returns axis of rotation encoded in this quaternion Generated from method MR::Quaterniond::axis.
Calls MR_Quaterniond_axis().
| auto meshlib::Quaterniond::b | ( | ) | const -> &f64 |
< imaginary part: b*i + c*j + d*k Returns a pointer to a member variable of class MR::Quaterniond named b.
Calls MR_Quaterniond_Get_b(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::b_mut | ( | ) | -> &mut f64 |
< imaginary part: b*i + c*j + d*k Returns a mutable pointer to a member variable of class MR::Quaterniond named b.
Calls MR_Quaterniond_GetMutable_b(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::c | ( | ) | const -> &f64 |
< imaginary part: b*i + c*j + d*k Returns a pointer to a member variable of class MR::Quaterniond named c.
Calls MR_Quaterniond_Get_c(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::c_mut | ( | ) | -> &mut f64 |
< imaginary part: b*i + c*j + d*k Returns a mutable pointer to a member variable of class MR::Quaterniond named c.
Calls MR_Quaterniond_GetMutable_c(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::call | ( | p:&meshlib::Vector3d | ) | const -> meshlib::Vector3d |
for unit quaternion returns the rotation of point p, which is faster to compute for single point; for multiple points it is faster to create matrix representation and apply it to the points Generated from method MR::Quaterniond::operator().
Calls MR_Quaterniond_call().
| auto meshlib::Quaterniond::conjugate | ( | ) | const -> meshlib::Owned< meshlib::Quaterniond > |
computes conjugate quaternion, which for unit quaternions encodes the opposite rotation Generated from method MR::Quaterniond::conjugate.
Calls MR_Quaterniond_conjugate().
|
static |
Generated from constructor MR::Quaterniond::Quaterniond.
Calls MR_Quaterniond_Construct_1(). The reference to the parameter m might be preserved in the constructed object.
|
static |
finds shorter arc rotation quaternion from one vector to another Generated from constructor MR::Quaterniond::Quaterniond.
Calls MR_Quaterniond_Construct_2_const_MR_Vector3d_ref_MR_Vector3d(). The reference to the parameter from might be preserved in the constructed object. The reference to the parameter to might be preserved in the constructed object.
|
static |
Generated from constructor MR::Quaterniond::Quaterniond.
Calls MR_Quaterniond_Construct_2_double(). The reference to the parameter im might be preserved in the constructed object.
|
static |
Generated from constructor MR::Quaterniond::Quaterniond.
Calls MR_Quaterniond_Construct_4().
|
static |
Generated from constructor MR::Quaterniond::Quaterniond.
Calls MR_Quaterniond_ConstructFromAnother(). The reference to things referred to by the parameter _other (if any) might be preserved in the constructed object.
| auto meshlib::Quaterniond::convert_to_mr_matrix3d | ( | ) | const -> meshlib::Matrix3d |
converts this into 3x3 rotation matrix Generated from conversion operator MR::Quaterniond::operator MR::Matrix3d.
Calls MR_Quaterniond_ConvertTo_MR_Matrix3d().
| auto meshlib::Quaterniond::d | ( | ) | const -> &f64 |
< imaginary part: b*i + c*j + d*k Returns a pointer to a member variable of class MR::Quaterniond named d.
Calls MR_Quaterniond_Get_d(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::d_mut | ( | ) | -> &mut f64 |
< imaginary part: b*i + c*j + d*k Returns a mutable pointer to a member variable of class MR::Quaterniond named d.
Calls MR_Quaterniond_GetMutable_d(). The reference to this object might be preserved as the return value.
| auto meshlib::Quaterniond::div_assign | ( | s:f64 | ) | -> &mut meshlib::Quaterniond |
Generated from method MR::Quaterniond::operator/=.
Calls MR_Quaterniond_div_assign(). The reference to this object might be preserved in the return value.
| auto meshlib::Quaterniond::im | ( | ) | const -> meshlib::Vector3d |
returns imaginary part of the quaternion as a vector Generated from method MR::Quaterniond::im.
Calls MR_Quaterniond_im().
| auto meshlib::Quaterniond::inverse | ( | ) | const -> meshlib::Owned< meshlib::Quaterniond > |
computes reciprocal quaternion Generated from method MR::Quaterniond::inverse.
Calls MR_Quaterniond_inverse().
|
static |
given t in [0,1], interpolates linearly two quaternions giving in general not-unit quaternion Generated from method MR::Quaterniond::lerp.
Calls MR_Quaterniond_lerp().
| auto meshlib::Quaterniond::mul_assign | ( | s:f64 | ) | -> &mut meshlib::Quaterniond |
Generated from method MR::Quaterniond::operator*=.
Calls MR_Quaterniond_mul_assign(). The reference to this object might be preserved in the return value.
|
static |
Constructs an empty (default-constructed) instance.
Calls MR_Quaterniond_DefaultConstruct().
| auto meshlib::Quaterniond::norm | ( | ) | const -> f64 |
Generated from method MR::Quaterniond::norm.
Calls MR_Quaterniond_norm().
| auto meshlib::Quaterniond::norm_sq | ( | ) | const -> f64 |
Generated from method MR::Quaterniond::normSq.
Calls MR_Quaterniond_normSq().
| void meshlib::Quaterniond::normalize | ( | ) |
scales this quaternion to make its norm unit Generated from method MR::Quaterniond::normalize.
Calls MR_Quaterniond_normalize().
| auto meshlib::Quaterniond::normalized | ( | ) | const -> meshlib::Owned< meshlib::Quaterniond > |
Generated from method MR::Quaterniond::normalized.
Calls MR_Quaterniond_normalized().
| auto meshlib::Quaterniond::op_neg | ( | ) | const -> meshlib::Owned< meshlib::Quaterniond > |
returns quaternion representing the same rotation, using the opposite rotation direction and opposite angle Generated from method MR::Quaterniond::operator-.
Calls MR_neg_MR_Quaterniond().
| void meshlib::Quaterniond::set_a | ( | value:f64 | ) |
< real part of the quaternion Modifies a member variable of class MR::Quaterniond named a.
Calls MR_Quaterniond_Set_a().
| void meshlib::Quaterniond::set_b | ( | value:f64 | ) |
< imaginary part: b*i + c*j + d*k Modifies a member variable of class MR::Quaterniond named b.
Calls MR_Quaterniond_Set_b().
| void meshlib::Quaterniond::set_c | ( | value:f64 | ) |
< imaginary part: b*i + c*j + d*k Modifies a member variable of class MR::Quaterniond named c.
Calls MR_Quaterniond_Set_c().
| void meshlib::Quaterniond::set_d | ( | value:f64 | ) |
< imaginary part: b*i + c*j + d*k Modifies a member variable of class MR::Quaterniond named d.
Calls MR_Quaterniond_Set_d().
|
static |
given t in [0,1] and two rotation matrices, interpolates them spherically and produces another rotation matrix Generated from method MR::Quaterniond::slerp.
Calls MR_Quaterniond_slerp_3_MR_Matrix3d().
|
static |
given t in [0,1] and two unit quaternions, interpolates them spherically and produces another unit quaternion Generated from method MR::Quaterniond::slerp.
Calls MR_Quaterniond_slerp_3_MR_Quaterniond().
|
static |
given t in [0,1] and rigid transformations, interpolates them spherically and produces another rigid transformation; p is the only point that will have straight line movement during interpolation Generated from method MR::Quaterniond::slerp.
Calls MR_Quaterniond_slerp_4().
|
Generated from constructor MR::Quaterniond::Quaterniond.
Calls MR_Quaterniond_Construct_2_const_MR_Vector3d_ref_double(). The reference to the parameter axis might be preserved in the constructed object.
 1.14.0