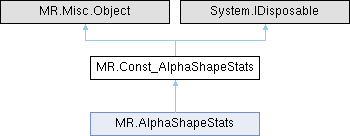
the amount of work done during the search of alpha-shape triangles; every function below only increases the counters, never resets them, so the statistics of several calls can be accumulated in one object Generated from class MR.AlphaShapeStats. This is the const half of the class.
More...
|
| virtual unsafe void | Dispose (bool disposing) |
|
| unsafe nuint | collectedNeis [get] |
| | the number of neighbours found within the search radius, before any of the filters below; the searches around all the points are quadratic in this, so it explains most of the difference in the time spent per point between one cloud and another
|
| unsafe nuint | redundancyTests [get] |
| | the number of pairs of neighbours checked for one of them making the other redundant, which is quadratic in the neighbours of a point
|
| unsafe nuint | redundantNeis [get] |
| | the number of neighbours found redundant by those checks and excluded from the search
|
| unsafe nuint | consideredTris [get] |
| | the number of triangles considered: the triples of close enough points that were checked for the existence of a ball of the given radius passing via all three of them
|
| unsafe nuint | touchableTris [get] |
| | the number of considered triangles touchable by the ball of the given radius, for each of which two balls (one from each side of the triangle) were tested for emptiness
|
| unsafe nuint | inBallTests [get] |
| | the number of point-in-ball tests performed for the balls of touchable triangles; less than 2 * touchableTris * (points in the neighbourhood) because a ball is not tested further as soon as the first point inside it is found
|
| unsafe nuint | shadowTests [get] |
| | the number of neighbours tested for being shadowed by the balls of a touchable triangle
|
| unsafe nuint | exactShadowTests [get] |
| | the number of shadow tests not decided by the floating-point rejection, which had to evaluate the exact predicates
|
| unsafe nuint | shadowedNeis [get] |
| | the number of neighbours found shadowed, which are excluded from the search
|
the amount of work done during the search of alpha-shape triangles; every function below only increases the counters, never resets them, so the statistics of several calls can be accumulated in one object Generated from class MR.AlphaShapeStats. This is the const half of the class.
◆ Const_AlphaShapeStats() [1/4]
| unsafe MR.Const_AlphaShapeStats.Const_AlphaShapeStats |
( |
| ) |
|
|
inline |
Constructs an empty (default-constructed) instance.
◆ Const_AlphaShapeStats() [2/4]
| unsafe MR.Const_AlphaShapeStats.Const_AlphaShapeStats |
( |
nuint | collectedNeis, |
|
|
nuint | redundancyTests, |
|
|
nuint | redundantNeis, |
|
|
nuint | consideredTris, |
|
|
nuint | touchableTris, |
|
|
nuint | inBallTests, |
|
|
nuint | shadowTests, |
|
|
nuint | exactShadowTests, |
|
|
nuint | shadowedNeis ) |
|
inline |
◆ Const_AlphaShapeStats() [3/4]
◆ Const_AlphaShapeStats() [4/4]
◆ Dispose() [1/2]
| virtual void MR.Const_AlphaShapeStats.Dispose |
( |
| ) |
|
|
inlinevirtual |
◆ Dispose() [2/2]
| virtual unsafe void MR.Const_AlphaShapeStats.Dispose |
( |
bool | disposing | ) |
|
|
inlineprotectedvirtual |
◆ __ref_storage_collectedNeis
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_collectedNeis |
|
protected |
◆ __ref_storage_consideredTris
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_consideredTris |
|
protected |
◆ __ref_storage_exactShadowTests
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_exactShadowTests |
|
protected |
◆ __ref_storage_inBallTests
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_inBallTests |
|
protected |
◆ __ref_storage_redundancyTests
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_redundancyTests |
|
protected |
◆ __ref_storage_redundantNeis
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_redundantNeis |
|
protected |
◆ __ref_storage_shadowedNeis
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_shadowedNeis |
|
protected |
◆ __ref_storage_shadowTests
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_shadowTests |
|
protected |
◆ __ref_storage_touchableTris
| unsafe nuint* MR.Const_AlphaShapeStats.__ref_storage_touchableTris |
|
protected |
◆ collectedNeis
| unsafe nuint MR.Const_AlphaShapeStats.collectedNeis |
|
get |
the number of neighbours found within the search radius, before any of the filters below; the searches around all the points are quadratic in this, so it explains most of the difference in the time spent per point between one cloud and another
◆ consideredTris
| unsafe nuint MR.Const_AlphaShapeStats.consideredTris |
|
get |
the number of triangles considered: the triples of close enough points that were checked for the existence of a ball of the given radius passing via all three of them
◆ exactShadowTests
| unsafe nuint MR.Const_AlphaShapeStats.exactShadowTests |
|
get |
the number of shadow tests not decided by the floating-point rejection, which had to evaluate the exact predicates
◆ inBallTests
| unsafe nuint MR.Const_AlphaShapeStats.inBallTests |
|
get |
the number of point-in-ball tests performed for the balls of touchable triangles; less than 2 * touchableTris * (points in the neighbourhood) because a ball is not tested further as soon as the first point inside it is found
◆ redundancyTests
| unsafe nuint MR.Const_AlphaShapeStats.redundancyTests |
|
get |
the number of pairs of neighbours checked for one of them making the other redundant, which is quadratic in the neighbours of a point
◆ redundantNeis
| unsafe nuint MR.Const_AlphaShapeStats.redundantNeis |
|
get |
the number of neighbours found redundant by those checks and excluded from the search
◆ shadowedNeis
| unsafe nuint MR.Const_AlphaShapeStats.shadowedNeis |
|
get |
the number of neighbours found shadowed, which are excluded from the search
◆ shadowTests
| unsafe nuint MR.Const_AlphaShapeStats.shadowTests |
|
get |
the number of neighbours tested for being shadowed by the balls of a touchable triangle
◆ touchableTris
| unsafe nuint MR.Const_AlphaShapeStats.touchableTris |
|
get |
the number of considered triangles touchable by the ball of the given radius, for each of which two balls (one from each side of the triangle) were tested for emptiness
The documentation for this class was generated from the following file:
 1.14.0