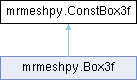
|
MeshLib Python Docs
|
|
MeshLib Python Docs
|
Public Member Functions | |
| bool | __eq__ (self, ConstBox3f a) |
| ConstVector3f | __getitem__ (self, int e) |
| __init__ (self, *args, **kwargs) | |
| bool | __ne__ (self, ConstBox3f a) |
| str | __repr__ (self) |
| typing.Any | __rlshift__ (self, typing.Any box) |
| Vector3f | center (self) |
| bool | contains (self, ConstVector3f pt) |
| bool | contains (self, ConstBox3f otherbox) |
| Vector3f | corner (self, ConstVector3b c) |
| float | diagonal (self) |
| Box3f | expanded (self, ConstVector3f expansion) |
| Vector3f | getBoxClosestPointTo (self, ConstVector3f pt) |
| float | getDistanceSq (self, ConstBox3f b) |
| float | getDistanceSq (self, ConstVector3f pt) |
| Vector3f | getProjection (self, ConstVector3f pt) |
| Box3f | insignificantlyExpanded (self) |
| Box3f | intersection (self, ConstBox3f b) |
| bool | intersects (self, ConstBox3f b) |
| Vector3f | size (self) |
| bool | valid (self) |
| float | volume (self) |
| ConstVector3f | max (self) |
| ConstVector3f | min (self) |
Static Public Member Functions | |
| Box3f | fromMinAndSize (ConstVector3f min, ConstVector3f size) |
| Vector3b | getMaxBoxCorner (ConstVector3f n) |
| Vector3b | getMinBoxCorner (ConstVector3f n) |
Static Public Attributes | |
| typing | elements = 3 |
Static Protected Attributes | |
| typing | _offsetof_max = 12 |
| typing | _offsetof_min = 0 |
Generated from:  MR::Box3f
Aliases:  AABBTreeBase_AABBTreeTraits_UndirectedEdgeTag_Box3f.BoxT, AABBTreeBase_ObjTreeTraits.BoxT, AABBTreeNode_AABBTreeTraits_UndirectedEdgeTag_Box3f.BoxT, AABBTreeNode_ObjTreeTraits.BoxT, AABBTreeTraits_UndirectedEdgeTag_Box3f.BoxT, ObjTreeTraits.BoxT, Vector_Box3f.const_pointer, Vector_Box3f.const_reference, Vector_Box3f.pointer, Vector_Box3f.reference, Vector_Box3f.value_type

Box given by its min- and max- corners
| mrmeshpy.ConstBox3f.__init__ | ( | self, | |
| * | args, | ||
| ** | kwargs ) |
__init__(*args, **kwargs)
Overloaded function.

1. __init__(self: meshlib.mrmeshpy.ConstBox3f) -> None

create invalid box by default

2. __init__(self: meshlib.mrmeshpy.ConstBox3f, min: meshlib.mrmeshpy.ConstVector3f, max: meshlib.mrmeshpy.ConstVector3f) -> None

3. __init__(self: meshlib.mrmeshpy.ConstBox3f, : meshlib.mrmeshpy.ConstNoInit) -> None

If the compiler supports `requires`, use that instead of `std::enable_if` here.
Not (only) because it looks cooler, but because of a bug in our binding generator that makes it choke on it: https://github.com/MeshInspector/mrbind/issues/19

4. __init__(self: meshlib.mrmeshpy.ConstBox3f, arg0: meshlib.mrmeshpy.Box3f) -> None

Implicit copy constructor.

5. __init__(self: meshlib.mrmeshpy.ConstBox3f, : meshlib.mrmeshpy.Box3f) -> None
| bool mrmeshpy.ConstBox3f.__eq__ | ( | self, | |
| ConstBox3f | a ) |
| ConstVector3f mrmeshpy.ConstBox3f.__getitem__ | ( | self, | |
| int | e ) |
min/max access by 0/1 index
| bool mrmeshpy.ConstBox3f.__ne__ | ( | self, | |
| ConstBox3f | a ) |
| str mrmeshpy.ConstBox3f.__repr__ | ( | self | ) |
| typing.Any mrmeshpy.ConstBox3f.__rlshift__ | ( | self, | |
| typing.Any | box ) |
| Vector3f mrmeshpy.ConstBox3f.center | ( | self | ) |
computes center of the box
| bool mrmeshpy.ConstBox3f.contains | ( | self, | |
| ConstBox3f | otherbox ) |
checks whether given box is fully inside (the surfaces may touch) of this box
| bool mrmeshpy.ConstBox3f.contains | ( | self, | |
| ConstVector3f | pt ) |
checks whether given point is inside (including the surface) of this box
| Vector3f mrmeshpy.ConstBox3f.corner | ( | self, | |
| ConstVector3b | c ) |
returns the corner of this box as specified by given bool-vector:
0 element in (c) means take min's coordinate,
1 element in (c) means take max's coordinate
| float mrmeshpy.ConstBox3f.diagonal | ( | self | ) |
computes length from min to max
| Box3f mrmeshpy.ConstBox3f.expanded | ( | self, | |
| ConstVector3f | expansion ) |
decreases min and increased max on given value
|
static |
| Vector3f mrmeshpy.ConstBox3f.getBoxClosestPointTo | ( | self, | |
| ConstVector3f | pt ) |
returns closest point in the box to given point
| float mrmeshpy.ConstBox3f.getDistanceSq | ( | self, | |
| ConstBox3f | b ) |
returns squared distance between this box and given one;
returns zero if the boxes touch or intersect
| float mrmeshpy.ConstBox3f.getDistanceSq | ( | self, | |
| ConstVector3f | pt ) |
returns squared distance between this box and given point;
returns zero if the point is inside or on the boundary of the box
|
static |
considering all planes with given normal and arbitrary shift: dot(n,x) = d
finds the box's corner for which d is maximal
|
static |
considering all planes with given normal and arbitrary shift: dot(n,x) = d
finds the box's corner for which d is minimal
| Vector3f mrmeshpy.ConstBox3f.getProjection | ( | self, | |
| ConstVector3f | pt ) |
returns the closest point on the box to the given point
for points outside the box this is equivalent to getBoxClosestPointTo
| Box3f mrmeshpy.ConstBox3f.insignificantlyExpanded | ( | self | ) |
decreases min and increases max to their closest representable value
| Box3f mrmeshpy.ConstBox3f.intersection | ( | self, | |
| ConstBox3f | b ) |
computes intersection between this and other box
| bool mrmeshpy.ConstBox3f.intersects | ( | self, | |
| ConstBox3f | b ) |
checks whether this box intersects or touches given box
| ConstVector3f mrmeshpy.ConstBox3f.max | ( | self | ) |
Reimplemented in mrmeshpy.Box3f, and mrmeshpy.Box3f.
| ConstVector3f mrmeshpy.ConstBox3f.min | ( | self | ) |
Reimplemented in mrmeshpy.Box3f, and mrmeshpy.Box3f.
| Vector3f mrmeshpy.ConstBox3f.size | ( | self | ) |
computes size of the box in all dimensions
| bool mrmeshpy.ConstBox3f.valid | ( | self | ) |
true if the box contains at least one point
| float mrmeshpy.ConstBox3f.volume | ( | self | ) |
computes the volume of this box
|
staticprotected |
|
staticprotected |
|
static |
 1.14.0