|
MeshLib Python Docs
|
|
MeshLib Python Docs
|
Public Member Functions | |
| Matrix3d | __add__ (self, ConstMatrix3d b) |
| bool | __eq__ (self, ConstMatrix3d b) |
| ConstVector3d | __getitem__ (self, int row) |
| __init__ (self, *args, **kwargs) | |
| Matrix3d | __mul__ (self, float a) |
| Vector3d | __mul__ (self, ConstVector3d b) |
| Matrix3d | __mul__ (self, ConstMatrix3d b) |
| bool | __ne__ (self, ConstMatrix3d b) |
| str | __repr__ (self) |
| typing.Any | __rlshift__ (self, typing.Any mat) |
| Matrix3d | __rmul__ (self, float b) |
| Matrix3d | __sub__ (self, ConstMatrix3d b) |
| Matrix3d | __truediv__ (self, float a) |
| Vector3d | col (self, int i) |
| float | det (self) |
| Matrix3d | inverse (self) |
| float | norm (self) |
| float | normSq (self) |
| Matrix3_double_QR | qr (self) |
| Vector3d | toEulerAngles (self) |
| float | trace (self) |
| Matrix3d | transposed (self) |
| ConstVector3d | x (self) |
| ConstVector3d | y (self) |
| ConstVector3d | z (self) |
Static Public Member Functions | |
| Matrix3d | approximateLinearRotationMatrixFromEuler (ConstVector3d eulerAngles) |
| Matrix3d | fromColumns (ConstVector3d x, ConstVector3d y, ConstVector3d z) |
| Matrix3d | fromRows (ConstVector3d x, ConstVector3d y, ConstVector3d z) |
| Matrix3d | identity () |
| Matrix3d | rotation (ConstVector3d axis, float angle) |
| Matrix3d | rotation (ConstVector3d from_, ConstVector3d to) |
| Matrix3d | rotationFromEuler (ConstVector3d eulerAngles) |
| Matrix3d | scale (float s) |
| Matrix3d | scale (float sx, float sy, float sz) |
| Matrix3d | scale (ConstVector3d s) |
| Matrix3d | zero () |
Static Protected Attributes | |
| typing | _offsetof_x = 0 |
| typing | _offsetof_y = 24 |
| typing | _offsetof_z = 48 |
Generated from:  MR::Matrix3d
Aliases:  AffineXf_Vector3d_M, Vector3_double_MatrixType

arbitrary 3x3 matrix
| mrmeshpy.ConstMatrix3d.__init__ | ( | self, | |
| * | args, | ||
| ** | kwargs ) |
__init__(*args, **kwargs)
Overloaded function.

1. __init__(self: meshlib.mrmeshpy.ConstMatrix3d, arg0: meshlib.mrmeshpy.ConstQuaterniond) -> None

converts this into 3x3 rotation matrix

2. __init__(self: meshlib.mrmeshpy.ConstMatrix3d) -> None

3. __init__(self: meshlib.mrmeshpy.ConstMatrix3d, x: meshlib.mrmeshpy.ConstVector3d, y: meshlib.mrmeshpy.ConstVector3d, z: meshlib.mrmeshpy.ConstVector3d) -> None

initializes matrix from its 3 rows

4. __init__(self: meshlib.mrmeshpy.ConstMatrix3d, arg0: meshlib.mrmeshpy.Matrix3d) -> None

Implicit copy constructor.

5. __init__(self: meshlib.mrmeshpy.ConstMatrix3d, : meshlib.mrmeshpy.Matrix3d) -> None
| Matrix3d mrmeshpy.ConstMatrix3d.__add__ | ( | self, | |
| ConstMatrix3d | b ) |
NOTE: We use `std::declval()` in the operators below because libclang 18 in our binding generator is bugged and chokes on decltyping `a.x` and such. TODO fix this when we update libclang.
| bool mrmeshpy.ConstMatrix3d.__eq__ | ( | self, | |
| ConstMatrix3d | b ) |
| ConstVector3d mrmeshpy.ConstMatrix3d.__getitem__ | ( | self, | |
| int | row ) |
row access
| Matrix3d mrmeshpy.ConstMatrix3d.__mul__ | ( | self, | |
| ConstMatrix3d | b ) |
product of two matrices
| Vector3d mrmeshpy.ConstMatrix3d.__mul__ | ( | self, | |
| ConstVector3d | b ) |
x = a * b
| Matrix3d mrmeshpy.ConstMatrix3d.__mul__ | ( | self, | |
| float | a ) |
| bool mrmeshpy.ConstMatrix3d.__ne__ | ( | self, | |
| ConstMatrix3d | b ) |
| str mrmeshpy.ConstMatrix3d.__repr__ | ( | self | ) |
| typing.Any mrmeshpy.ConstMatrix3d.__rlshift__ | ( | self, | |
| typing.Any | mat ) |
| Matrix3d mrmeshpy.ConstMatrix3d.__rmul__ | ( | self, | |
| float | b ) |
| Matrix3d mrmeshpy.ConstMatrix3d.__sub__ | ( | self, | |
| ConstMatrix3d | b ) |
| Matrix3d mrmeshpy.ConstMatrix3d.__truediv__ | ( | self, | |
| float | a ) |
|
static |
returns linear by angles approximation of the rotation matrix, which is close to true rotation matrix for small angles
| Vector3d mrmeshpy.ConstMatrix3d.col | ( | self, | |
| int | i ) |
column access
| float mrmeshpy.ConstMatrix3d.det | ( | self | ) |
computes determinant of the matrix
|
static |
constructs a matrix from its 3 columns;
use this method to get the matrix that transforms basis vectors ( plusX, plusY, plusZ ) into vectors ( x, y, z ) respectively
|
static |
constructs a matrix from its 3 rows
|
static |
| Matrix3d mrmeshpy.ConstMatrix3d.inverse | ( | self | ) |
computes inverse matrix
| float mrmeshpy.ConstMatrix3d.norm | ( | self | ) |
| float mrmeshpy.ConstMatrix3d.normSq | ( | self | ) |
compute sum of squared matrix elements
| Matrix3_double_QR mrmeshpy.ConstMatrix3d.qr | ( | self | ) |
decompose this matrix on the product Q*R, where Q is orthogonal and R is upper triangular
|
static |
creates matrix representing rotation around given axis on given angle
|
static |
creates matrix representing rotation that after application to (from) makes (to) vector
|
static |
creates matrix representing rotation from 3 Euler angles: R=R(z)*R(y)*R(x)
see more https://en.wikipedia.org/wiki/Euler_angles#Conventions_by_intrinsic_rotations
|
static |
|
static |
returns a matrix that scales uniformly
|
static |
returns a matrix that has its own scale along each axis
| Vector3d mrmeshpy.ConstMatrix3d.toEulerAngles | ( | self | ) |
returns 3 Euler angles, assuming this is a rotation matrix composed as follows: R=R(z)*R(y)*R(x)
| float mrmeshpy.ConstMatrix3d.trace | ( | self | ) |
computes trace of the matrix
| Matrix3d mrmeshpy.ConstMatrix3d.transposed | ( | self | ) |
computes transposed matrix
| ConstVector3d mrmeshpy.ConstMatrix3d.x | ( | self | ) |
rows, identity matrix by default
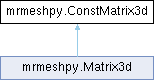
Reimplemented in mrmeshpy.Matrix3d, and mrmeshpy.Matrix3d.
| ConstVector3d mrmeshpy.ConstMatrix3d.y | ( | self | ) |
Reimplemented in mrmeshpy.Matrix3d, and mrmeshpy.Matrix3d.
| ConstVector3d mrmeshpy.ConstMatrix3d.z | ( | self | ) |
Reimplemented in mrmeshpy.Matrix3d, and mrmeshpy.Matrix3d.
|
static |
|
staticprotected |
|
staticprotected |
|
staticprotected |
 1.14.0