|
| unsafe | RigidXfRansacParams () |
| | Constructs an empty (default-constructed) instance.
|
| unsafe | RigidXfRansacParams (float inlierDistance, int maxIterations, float confidence, float edgeLengthRatio, uint seed, MR.Const_VertCoords? overlapSrcPoints, MR.Const_PointCloud? overlapTgtCloud, MR.Const_VertCoords? overlapTgtPoints, MR.Const_PointCloud? overlapSrcCloud) |
| | Constructs MR.RigidXfRansacParams elementwise.
|
| unsafe | RigidXfRansacParams (MR.Const_RigidXfRansacParams _other) |
| | Generated from constructor MR.RigidXfRansacParams.RigidXfRansacParams.
|
| | RigidXfRansacParams (RigidXfRansacParams _other) |
| | Generated from constructor MR.RigidXfRansacParams.RigidXfRansacParams.
|
| unsafe MR.RigidXfRansacParams | assign (MR.Const_RigidXfRansacParams _other) |
| | Generated from method MR::RigidXfRansacParams::operator=.
|
| virtual void | Dispose () |
| unsafe | Const_RigidXfRansacParams () |
| | Constructs an empty (default-constructed) instance.
|
| unsafe | Const_RigidXfRansacParams (float inlierDistance, int maxIterations, float confidence, float edgeLengthRatio, uint seed, MR.Const_VertCoords? overlapSrcPoints, MR.Const_PointCloud? overlapTgtCloud, MR.Const_VertCoords? overlapTgtPoints, MR.Const_PointCloud? overlapSrcCloud) |
| | Constructs MR.RigidXfRansacParams elementwise.
|
| unsafe | Const_RigidXfRansacParams (MR.Const_RigidXfRansacParams _other) |
| | Generated from constructor MR.RigidXfRansacParams.RigidXfRansacParams.
|
| | Const_RigidXfRansacParams (RigidXfRansacParams _other) |
| | Generated from constructor MR.RigidXfRansacParams.RigidXfRansacParams.
|
|
| new unsafe ref float | inlierDistance [get] |
| | a match is an inlier of a transformation if it maps the source point within this distance from the target point
|
| new unsafe ref int | maxIterations [get] |
| | the maximal number of random samples of three matches to test
|
| new unsafe ref float | confidence [get] |
| | the search stops earlier when the probability to have tested at least one sample of three inliers reaches this value
|
| new unsafe ref float | edgeLengthRatio [get] |
| | a sample is skipped without fitting if the distances between its source points and between its target points differ more than this ratio, since a rigid motion keeps distances
|
| new unsafe ref uint | seed [get] |
| | seed of pseudo-random sampling; the result depends on it but not on the number of threads
|
| new unsafe MR.? Const_VertCoords | overlapSrcPoints [get, set] |
| | if both are set, a transformation is scored by how many of these source points it moves within inlierDistance of some point of the target cloud, instead of by the number of its inlier matches; this finds the transformation even when only a few matches are correct, at the cost of a closest point search per point
|
| new unsafe MR.? Const_PointCloud | overlapTgtCloud [get, set] |
| new unsafe MR.? Const_VertCoords | overlapTgtPoints [get, set] |
| | if both are set, the score also counts how many of these target points the inverse transformation moves within inlierDistance of some point of the source cloud; can be set alone or together with the pair above
|
| new unsafe MR.? Const_PointCloud | overlapSrcCloud [get, set] |
| unsafe float | inlierDistance [get] |
| | a match is an inlier of a transformation if it maps the source point within this distance from the target point
|
| unsafe int | maxIterations [get] |
| | the maximal number of random samples of three matches to test
|
| unsafe float | confidence [get] |
| | the search stops earlier when the probability to have tested at least one sample of three inliers reaches this value
|
| unsafe float | edgeLengthRatio [get] |
| | a sample is skipped without fitting if the distances between its source points and between its target points differ more than this ratio, since a rigid motion keeps distances
|
| unsafe uint | seed [get] |
| | seed of pseudo-random sampling; the result depends on it but not on the number of threads
|
| unsafe MR.? Const_VertCoords | overlapSrcPoints [get] |
| | if both are set, a transformation is scored by how many of these source points it moves within inlierDistance of some point of the target cloud, instead of by the number of its inlier matches; this finds the transformation even when only a few matches are correct, at the cost of a closest point search per point
|
| unsafe MR.? Const_PointCloud | overlapTgtCloud [get] |
| unsafe MR.? Const_VertCoords | overlapTgtPoints [get] |
| | if both are set, the score also counts how many of these target points the inverse transformation moves within inlierDistance of some point of the source cloud; can be set alone or together with the pair above
|
| unsafe MR.? Const_PointCloud | overlapSrcCloud [get] |
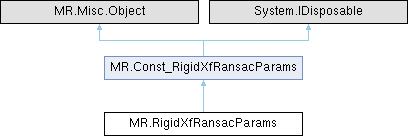
Generated from class MR.RigidXfRansacParams. This is the non-const half of the class.
 1.14.0