|
MeshLib Python Docs
|
|
MeshLib Python Docs
|
Public Member Functions | |
| __init__ (self, *args, **kwargs) | |
| int | calcNumValidPoints (self) |
| Box3f | computeBoundingBox (self, ConstAffineXf3f toWorld=None) |
| Box3f | computeBoundingBox (self, ConstVertBitSet region, ConstAffineXf3f toWorld=None) |
| Vector3f | findCenterFromBBox (self) |
| Vector3f | findCenterFromPoints (self) |
| ConstAABBTreePoints | getAABBTree (self) |
| ConstAABBTreePoints | getAABBTreeNotCreate (self) |
| Box3f | getBoundingBox (self) |
| std_vector_Id_VertTag | getLexicographicalOrder (self) |
| ConstVertBitSet | getVertIds (self, ConstVertBitSet region) |
| bool | hasNormals (self) |
| int | heapBytes (self) |
| ConstVertCoords | normals (self) |
| ConstVertCoords | points (self) |
| ConstVertBitSet | validPoints (self) |
Static Protected Attributes | |
| typing | _offsetof_normals = 24 |
| typing | _offsetof_points = 0 |
| typing | _offsetof_validPoints = 48 |
Generated from:  MR::PointCloud
Aliases:  std_shared_ptr_PointCloud, std_shared_ptr_const_PointCloud
| mrmeshpy.ConstPointCloud.__init__ | ( | self, | |
| * | args, | ||
| ** | kwargs ) |
__init__(*args, **kwargs)
Overloaded function.

1. __init__(self: meshlib.mrmeshpy.ConstPointCloud) -> None

2. __init__(self: meshlib.mrmeshpy.ConstPointCloud, arg0: meshlib.mrmeshpy.ConstPointCloud) -> None

Implicit copy constructor.

3. __init__(self: meshlib.mrmeshpy.ConstPointCloud, : meshlib.mrmeshpy.ConstPointCloud) -> None
| int mrmeshpy.ConstPointCloud.calcNumValidPoints | ( | self | ) |
computes the total number of valid points in the cloud
| Box3f mrmeshpy.ConstPointCloud.computeBoundingBox | ( | self, | |
| ConstAffineXf3f | toWorld = None ) |
passes through all valid points and finds the minimal bounding box containing all of them;
if toWorld transformation is given then returns minimal bounding box in world space
| Box3f mrmeshpy.ConstPointCloud.computeBoundingBox | ( | self, | |
| ConstVertBitSet | region, | ||
| ConstAffineXf3f | toWorld = None ) |
passes through all given vertices (or all valid vertices if region == null) and finds the minimal bounding box containing all of them
if toWorld transformation is given then returns minimal bounding box in world space
| Vector3f mrmeshpy.ConstPointCloud.findCenterFromBBox | ( | self | ) |
computes bounding box and returns its center
| Vector3f mrmeshpy.ConstPointCloud.findCenterFromPoints | ( | self | ) |
computes average position of all valid points
| ConstAABBTreePoints mrmeshpy.ConstPointCloud.getAABBTree | ( | self | ) |
returns cached aabb-tree for this point cloud, creating it if it did not exist in a thread-safe manner
| ConstAABBTreePoints mrmeshpy.ConstPointCloud.getAABBTreeNotCreate | ( | self | ) |
returns cached aabb-tree for this point cloud, but does not create it if it did not exist
| Box3f mrmeshpy.ConstPointCloud.getBoundingBox | ( | self | ) |
returns the minimal bounding box containing all valid vertices (implemented via getAABBTree())
| std_vector_Id_VertTag mrmeshpy.ConstPointCloud.getLexicographicalOrder | ( | self | ) |
returns all valid point ids sorted lexicographically by their coordinates (optimal for uniform sampling)
| ConstVertBitSet mrmeshpy.ConstPointCloud.getVertIds | ( | self, | |
| ConstVertBitSet | region ) |
if region pointer is not null then converts it in reference, otherwise returns all valid points in the cloud
| bool mrmeshpy.ConstPointCloud.hasNormals | ( | self | ) |
returns true if there is a normal for each point
| int mrmeshpy.ConstPointCloud.heapBytes | ( | self | ) |
returns the amount of memory this object occupies on heap
| ConstVertCoords mrmeshpy.ConstPointCloud.normals | ( | self | ) |
unit normal directions of points (can be empty if no normals are known)
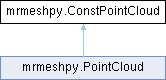
Reimplemented in mrmeshpy.PointCloud, and mrmeshpy.PointCloud.
| ConstVertCoords mrmeshpy.ConstPointCloud.points | ( | self | ) |
coordinates of points
Reimplemented in mrmeshpy.PointCloud, and mrmeshpy.PointCloud.
| ConstVertBitSet mrmeshpy.ConstPointCloud.validPoints | ( | self | ) |
only points and normals corresponding to set bits here are valid
Reimplemented in mrmeshpy.PointCloud, and mrmeshpy.PointCloud.
|
staticprotected |
|
staticprotected |
|
staticprotected |
 1.14.0