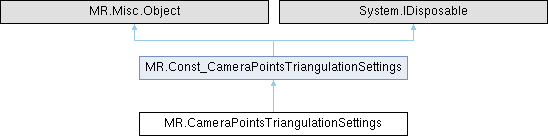
Generated from class MR.CameraPointsTriangulationSettings. This is the non-const half of the class.
More...
|
| new unsafe ref MR.Matrix3f | intrinsics [get] |
| | camera intrinsic matrix: the image-plane (pixel) position of a point p in camera space is ( K * p ).xy / ( K * p ).z
|
| new unsafe ref float | weldPixels [get] |
| | points closer than this distance in the image plane are merged into one vertex located at their average position; non-positive value disables merging
|
| new unsafe MR.? VertMap | outSmallestMap [get, set] |
| | if not null, receives the result of findSmallestCloseVertices on the image-plane positions: each point is mapped to the point it was merged into (or to itself); left unchanged if weldPixels <= 0
|
| new unsafe MR.? VertCoords | outProjectedPoints [get, set] |
| | if not null, receives the image-plane coordinates of all points as ( x, -y, 1 ) with y mirrored, for welded points these are the coordinates of the averaged position, for invalid cloud points zeros
|
| unsafe ref readonly MR.Matrix3f | intrinsics [get] |
| | camera intrinsic matrix: the image-plane (pixel) position of a point p in camera space is ( K * p ).xy / ( K * p ).z
|
| unsafe float | weldPixels [get] |
| | points closer than this distance in the image plane are merged into one vertex located at their average position; non-positive value disables merging
|
| unsafe MR.? VertMap | outSmallestMap [get] |
| | if not null, receives the result of findSmallestCloseVertices on the image-plane positions: each point is mapped to the point it was merged into (or to itself); left unchanged if weldPixels <= 0
|
| unsafe MR.? VertCoords | outProjectedPoints [get] |
| | if not null, receives the image-plane coordinates of all points as ( x, -y, 1 ) with y mirrored, for welded points these are the coordinates of the averaged position, for invalid cloud points zeros
|
Generated from class MR.CameraPointsTriangulationSettings. This is the non-const half of the class.
◆ CameraPointsTriangulationSettings() [1/4]
| unsafe MR.CameraPointsTriangulationSettings.CameraPointsTriangulationSettings |
( |
| ) |
|
|
inline |
Constructs an empty (default-constructed) instance.
◆ CameraPointsTriangulationSettings() [2/4]
| unsafe MR.CameraPointsTriangulationSettings.CameraPointsTriangulationSettings |
( |
MR.Matrix3f | intrinsics, |
|
|
float | weldPixels, |
|
|
MR.VertMap? | outSmallestMap, |
|
|
MR.VertCoords? | outProjectedPoints ) |
|
inline |
◆ CameraPointsTriangulationSettings() [3/4]
◆ CameraPointsTriangulationSettings() [4/4]
◆ assign()
Generated from method MR::CameraPointsTriangulationSettings::operator=.
◆ intrinsics
| new unsafe ref MR.Matrix3f MR.CameraPointsTriangulationSettings.intrinsics |
|
get |
camera intrinsic matrix: the image-plane (pixel) position of a point p in camera space is ( K * p ).xy / ( K * p ).z
◆ outProjectedPoints
| new unsafe MR.? VertCoords MR.CameraPointsTriangulationSettings.outProjectedPoints |
|
getset |
if not null, receives the image-plane coordinates of all points as ( x, -y, 1 ) with y mirrored, for welded points these are the coordinates of the averaged position, for invalid cloud points zeros
◆ outSmallestMap
| new unsafe MR.? VertMap MR.CameraPointsTriangulationSettings.outSmallestMap |
|
getset |
if not null, receives the result of findSmallestCloseVertices on the image-plane positions: each point is mapped to the point it was merged into (or to itself); left unchanged if weldPixels <= 0
◆ weldPixels
| new unsafe ref float MR.CameraPointsTriangulationSettings.weldPixels |
|
get |
points closer than this distance in the image plane are merged into one vertex located at their average position; non-positive value disables merging
The documentation for this class was generated from the following file:
 1.14.0